Loading...
Searching...
No Matches
auterion::surface_vehicle::GlobalFramePositionSetpoint::Config Class Reference
Mode-wide defaults for GlobalFramePositionSetpoint. More...
#include <auterion_sdk/control/surface_vehicle/global_frame_position_control.hpp>
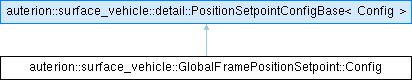
Inheritance diagram for auterion::surface_vehicle::GlobalFramePositionSetpoint::Config:
Additional Inherited Members | |
 Public Member Functions inherited from auterion::surface_vehicle::detail::PositionSetpointConfigBase< Config > | |
| Config & | withDefaultCruisingSpeed (float cruising_speed_m_s) |
| Sets the default cruising speed [m/s]. Negative drives to the target in reverse. Unset means the vehicle's maximum speed. | |
| Config & | withDefaultArrivalSpeed (float arrival_speed_m_s) |
| Sets the default speed the vehicle has when it reaches the target [m/s]. Default is 0, so the vehicle stops at the target. | |
| std::optional< float > | getDefaultCruisingSpeed () const |
| float | getDefaultArrivalSpeed () const |
Detailed Description
Mode-wide defaults for GlobalFramePositionSetpoint.
The values set here are used when a setpoint leaves them unset.
The documentation for this class was generated from the following file:
- include/auterion_sdk/control/surface_vehicle/global_frame_position_control.hpp
